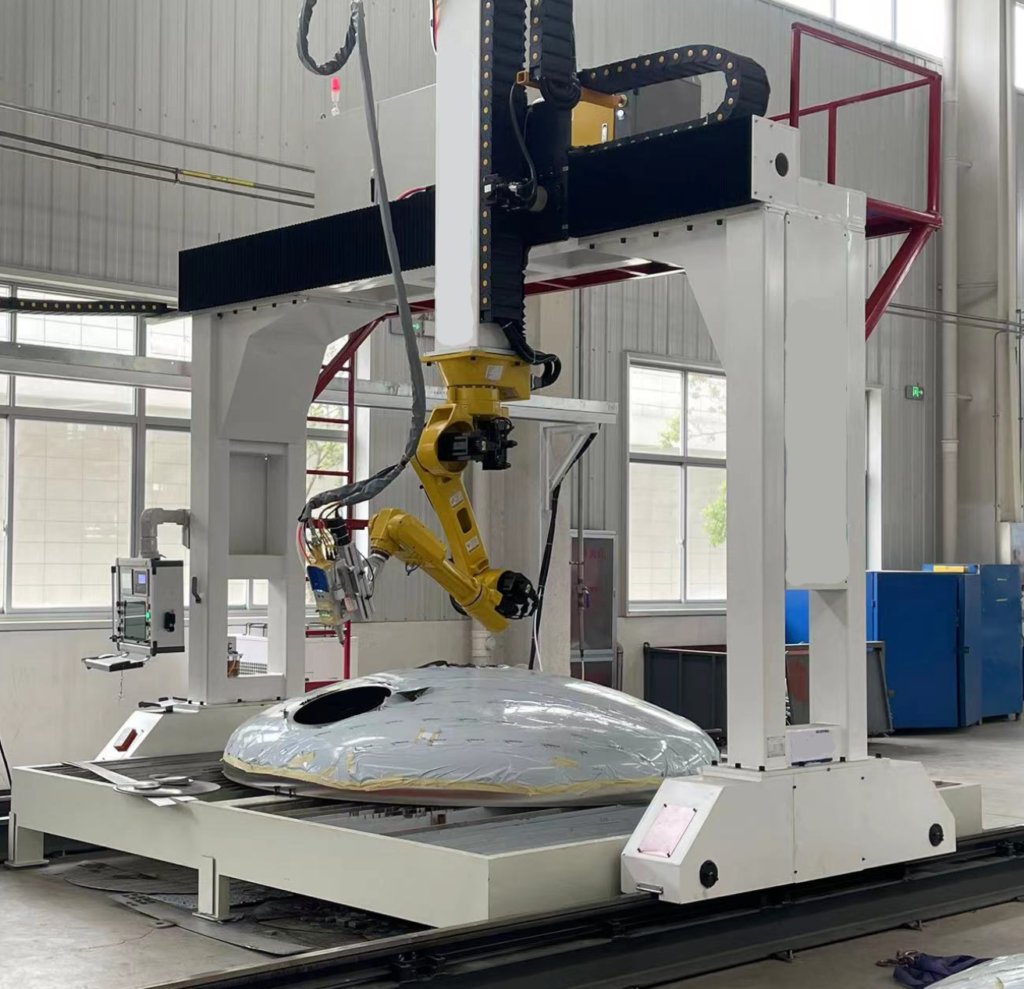
The Gantry-type 3D Laser Cutting Robot Workstation is a high-precision, efficient cutting solution. It features an inverted six-axis robot mounted on a gantry structure, expanding the working range and enabling complex curved surface cutting. The 3D laser cutting head, equipped with anti-collision and anti-tangling systems, can achieve high-flexibility rotary cutting with a large working radius. The workstation supports various worktable types and fixtures for flexible production. It is widely used in automotive, new energy, and smart home appliance industries, offering high precision, large cutting speed, and configurable laser power.
Structure and Detailed Description of Gantry-type 3D Laser Cutting Robot Workstation (Including 3D Laser Cutting and Inverted Six-axis Robot)
1. Gantry Structure
Beam and Legs: The gantry consists of two vertical legs and a horizontal beam, providing a stable platform for the robot to ensure precision and stability during the cutting process.
Support Guide Rails: Fixed on the front side of the gantry, the support guide rails are used for the six-axis robot’s left-right sliding connection through its guide slots, offering positioning and guidance for the robot’s movement.
2. Inverted Six-axis Robot
Mounting Method: The six-axis robot is mounted upside down on the middle of the gantry beam, which expands the robot’s working range.
Drive Mechanism: The robot slides left and right on the gantry through a drive mechanism, which includes a rack fixed on the top surface of the gantry and a drive gear meshing with it, driven by a rotary motor.
Functional Features: The six-axis robot is characterized by high precision, high rigidity, and high flexibility, enabling complex curved surface cutting.
3. 3D Laser Cutting Head
Mounting Method: The 3D laser cutting head is installed on the end-connection plate of the six-axis robot.
Functional Features: Equipped with a dedicated 3D laser cutting head and anti-collision, anti-tangling systems, the cutting head can achieve 360-degree high-flexibility rotary cutting with a working radius of up to 2 meters. In the event of a collision, the cutting head can quickly reset to minimize cable tangling.
Auxiliary Function: The cutting head is connected to an air pipe, through which an external air source provides high-pressure gas to blow away the molten material generated during laser cutting.
4. Worktable and Exchange Platform
Worktable Base: The worktable base is equipped with linear guide rails.
Exchange Platform: The bottom of the exchange platform is fitted with sliders that cooperate with the linear guide rails, allowing the platform to slide along them. The platform is equipped with first and second fixtures for holding workpieces to be cut.
Drive Mechanism: Between the exchange platform and the worktable base, there is an exchange drive mechanism that enables the platform’s reciprocating motion through a servo motor and rack-and-pinion transmission.
5. Control System
Control Cabinet: The control cabinet includes a controller and an enclosure. The controller is connected to a control switch group and a CCD display. The control switch group is connected to a height adjuster, which is linked to the six-axis robot.
Laser Source: Inside the control cabinet, there is a laser source connected to the cutting head via an optical fiber. The laser source, optical fiber, and cutting head are all wrapped with water pipes, forming a closed loop with a water chiller.
6. Other Auxiliary Equipment
Water Chiller: A water chiller is located on one side of the gantry to cool the laser source and cutting head.
Micro-adjustment Mechanism: In the end-cap support and fixing mechanism, the support and fixing seat is connected to a micro-adjustment mechanism. By manually rotating the handwheel, the distance between the support and fixing seat and the workpiece can be adjusted.
Technical Advantages of 3D Laser Cutting and Inverted Six-axis Robot
High-Precision Cutting: 3D laser cutting technology enables high-precision cutting, suitable for processing complex shapes and curved surfaces.
Efficient Processing: The inverted six-axis robot expands the working space, improving processing efficiency, especially for large and extra-long workpieces.
Flexible Production: The workstation supports various mounting methods and customized fixtures, meeting the flexible processing needs of different industries for small and medium batch sizes and a variety of products.
This gantry-type 3D laser cutting robot workstation is widely used in high-end fields such as automotive manufacturing, new energy, smart wearables, and intelligent home appliances.
Parameter Tables
Gantry-type 3D Laser Cutting Robot Workstation Parameters
Design assembly lines by first defining product BOM, process KCs and required takt. Simulate line balance and ergonomics to ≥87 % efficiency, then create a clash-free 3D layout with digital twin. Manufacture modules under FAT criteria: Cpk ≥1.33, ≤1 stop/8 h. Commission in five steps—hardware, no-load, load, line no-load, line load—until OEE ≥85 %. Use…
Stainless steel joint laser welding combined with automated production lines offers a highly efficient and precise manufacturing solution. Key parameters include laser power (50W–4kW), welding speed (0.1–10m/min), pulse parameters (width, frequency, duty cycle), defocusing amount, and protective gas flow. The process involves material preparation, clamping, tack welding, edge misalignment adjustment, formal welding, and post-weld inspection….
Customizing a product assembly line follows a structured seven-step process: requirement analysis, preliminary design, drawing approval, precision manufacturing, on-site installation, trial-run acceptance, and after-sales support. Each phase is customer-driven, balancing throughput targets, automation level, space constraints and budget. Designs specify line layout, conveyor type, workstation number, control architecture and safety systems. Parts are machined, tested,…
Customizing a PLC control system for production lines involves several key steps. First, conduct a thorough requirement analysis to identify controlled objects, understand the production process, and determine control functions and performance needs. Next, formulate a detailed scheme, including hardware selection (PLC host, I/O modules, power supply, communication modules, etc.) and software design (programming language,…
تحتاج ورشة التجميع عادةً إلى معدات تُصنَّف حسب ست خطوات عملية: الاستلام، المعالجة الأولية، التجميع الجزئي، التجميع النهائي، الفحص والتعبئة. تتضمن الآلات الأساسية رافعات الشحن، منظفات الموجات فوق الصوتية، سيور السلسلة التفاضلية، مكابس السيرفو، عربات الإمداد AGV، روبوتات ستة محاور، أجهزة القياس ثلاثية الإحداثيات، وآلات التعبئة الأوتوماتيكية. تشمل مرافق الخدمات ضواغط الهواء، المبردات، مولدات النيتروجين…
A Free Flow Chain Conveyor is an efficient conveying system specifically designed for assembly lines. It typically consists of a series of chains with freely rotating support rollers that can support and move workpieces or products placed on them. Here is a description of the Free Flow Chain Conveyor: The Free Flow Chain Conveyor is…